
Blog posts tagged "ROS 2"
ROS 2 gives robotics developers the freedom to choose the middleware that fits their system. As a communication protocol for ROS, Zenoh has gained strong...
Ubuntu is the home of ROS. The very first ROS distribution, Box Turtle, launched on Ubuntu 8.04 LTS, Hardy Heron, and since then, Ubuntu and ROS have grown...
As of May 2025, the Robot Operating System (ROS) Noetic Ninjemys officially reached its end of life (EOL). First released in 2020 as the final ROS (1)...
The TurtleBot3 robot is a standard platform robot in the ROS community, and it’s a reference that Canonical knows well, since we’ve used it in our tutorials....
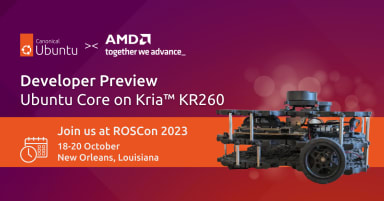
The robotics field is constantly evolving, and with AMD and Canonical’s collaboration, the trajectory towards a more adaptable and efficient robotics...
Choosing the right architecture can be hard, but we want to help. In this blog, we’ll look at different architectures and their pros and cons. We’ll also show...
Historically ROS has been developed on top of Ubuntu, relying on the distribution as a stable base providing tools (like GCC, CMake, Python to name a few) and...
Welcome to Part 6 of our “Optimise your ROS snap” blog series. Make sure to check Part 5. This sixth and final part will summarise every optimisation that we...
Welcome to Part 5 of our “Optimise your ROS snap” blog series. Make sure to check Part 4. This fifth part is going to cover two different optimisations. The...
Welcome to Part 4 of our “optimise your ROS snap” blog series. Make sure to check Part 3 before. This fourth part is going to explain what dynamic library...
Welcome to Part 3 of our “optimise your ROS snap” blog series. Make sure to check Part 2. This third part is going to present safe optimisations consisting of...
Welcome to Part 2 of the “optimise your ROS snap” blog series. Make sure to check Part 1 before reading this blog post. This second part is going to present...
Do you want to optimise the performance of your ROS snap? We reduced the size of the installed Gazebo snap by 95%! This is how you can do it for your snap....

We are happy to announce the release of our first e-training course for deploying ROS applications in The Construct. The Construct is the leading e-learning...
ROS Melodic EOL is around the corner. With more than 1,004 repositories in rosdistro, Melodic is among the top 3 ROS distributions (with Indigo and Kinetic)....
It’s a new year, and an especially great time to reflect on the security of your robots. After all, those interested in breaching it are probably doing the...